 Compare
 Sign in
Choose a robot architecture
Start with the motion your application needs.

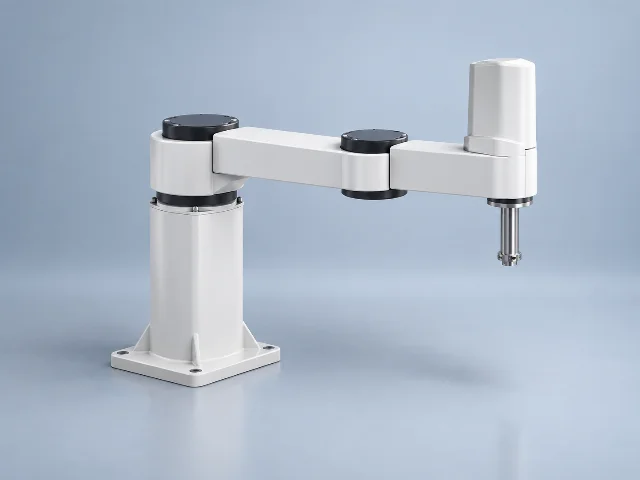
Delta robots
Parallel-link architecture for pick-and-place operations.
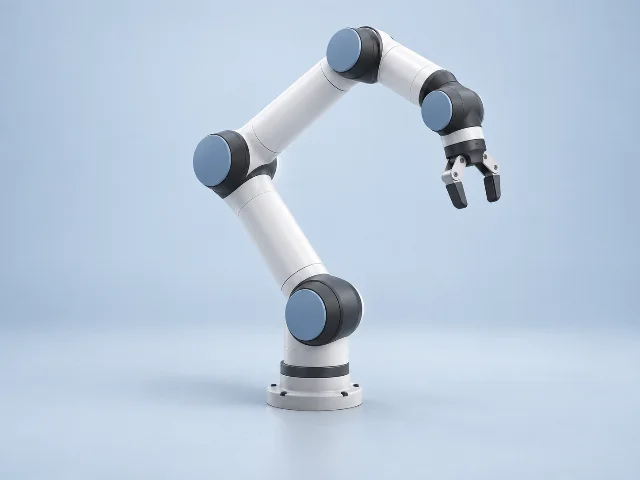
Cartesian robots
Linear-axis architecture for rectangular work envelopes.
Robot finishing tools
End-of-arm tools for robotic grinding, polishing and deburring. These tools require a compatible robot or automation cell and are not complete robot arms.
Autonomous forklifts
Autonomous forklift and side-loading AGV products for warehouse pallet handling. Compare load limits at the required lifting height, aisle clearance and pallet compatibility; lifting height is not robot-arm reach.
Robot tool changers
Robot-side and tool-side couplings for changing end-of-arm equipment. Compare coupling load ratings, pneumatic requirements and connection circuits; these components are not complete robot arms.